Sloshing in partially filled propellant tanks can strongly affect the dynamics of launch vehicles. The motion of the liquid generates time-dependent forces, torques and pressure fluctuations, which can interact with the vehicle structure, propulsion system and attitude-control dynamics. Predicting and mitigating these effects is therefore an important problem in launch-vehicle design.
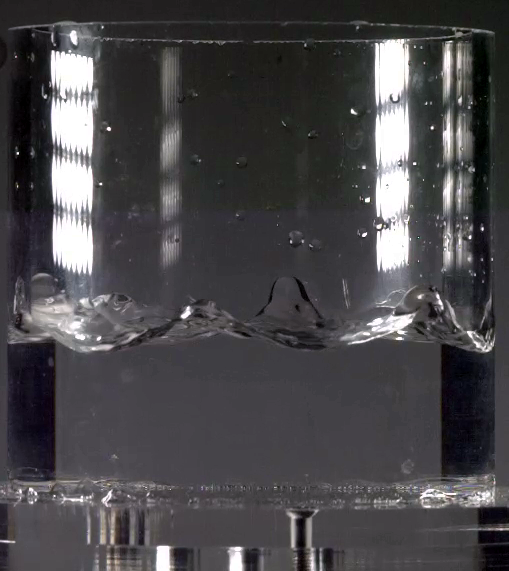
My work on sloshing began during my Bachelor’s thesis with the EPFL Rocket Team, at a time when the team was developing its first bipropellant launch vehicles. Rather than relying on conventional internal baffles, which would have added significant manufacturing complexity, I investigated passive damping strategies acting directly at the free surface.
The starting point was a simple physical observation: for viscous sloshing, a significant part of the dissipation is concentrated close to the free surface and the surrounding boundaries. This suggested that strong damping could potentially be achieved by modifying only a small fraction of the tank volume, while leaving the bulk propellant essentially unchanged.

We therefore investigated a two-phase damping concept in which floating beads form a dissipative layer at the liquid surface. Laboratory experiments showed that this layer can substantially reduce the amplitude of the global sloshing motion. They also revealed an important limitation: if gaps develop in the bead layer, localized free-surface oscillations can persist through these openings and progressively excite the entire tank. Effective damping therefore requires a sufficiently dense and continuous surface layer.
The concept was subsequently taken from the laboratory to a flight experiment. Together with the Rocket Team’s payload division, I designed a compact sloshing experiment integrated into a 3U CanSat payload and flown aboard Wildhorn, the team’s supersonic rocket.
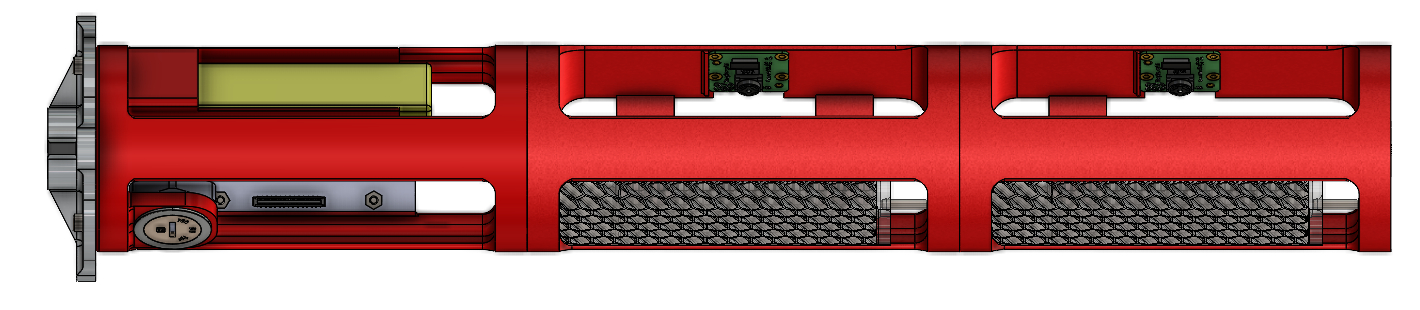
The flight demonstrated that the granular surface layer can effectively suppress sloshing under realistic launch conditions. During the propulsion phase, sustained axial acceleration kept the granular layer compact and cohesive, strongly limiting free-surface motion. During the subsequent free-flight phase, however, the loss of apparent gravity caused the layer to disperse and the damping mechanism to break down.
These results revealed an important physical limitation of the concept: granular sloshing mitigation is gravity-dependent. It is therefore particularly suited to phases involving sustained acceleration, such as launch-vehicle first stages or sounding rockets, but is not expected to remain effective during extended ballistic or microgravity conditions.
In parallel with this applied work, I investigated viscous sloshing from a more fundamental perspective. I developed and experimentally validated a theoretical model for viscous sloshing in low-filled rectangular tanks, providing predictions of the free-surface dynamics and damping across different viscosities and filling levels. This work was carried out in collaboration with Benjamin Meunier and Professor Daniele Mari and is the subject of an ongoing publication.
[Back to Homepage]List of publications
- Sloshing of a viscous fluid in low filled rectangular tanks, Submitted (2026)., Maxime C.N. Roux, Benjamin A.H. Meunier and Daniele Mari
- In-Flight Investigation of Floating Beads for Sloshing Mitigation for Liquid-Fueled Rockets, Key Engineering Materials 1062 (2026), 53-60., Maxime C.N. Roux, Benjamin A.H. Meunier, Loup Cordey and Daniele Mari, (DOI)
- Study of Faraday waves in tanks in presence of polystyrene bead layers, Emergent Scientist 7 (2023), Maxime C.N. Roux, Benjamin A.H. Meunier and Daniele Mari, (DOI)
- Sloshing of viscous fluids: Application to aerospace, arXiv (2021), Benjamin A.H. Meunier and Maxime C.N. Roux, (DOI)
List of talks and conferences
- 20th International Conference on Internal Friction and Mechanical Spectroscopy, Lausanne, July 2025: Using granular materials to damp sloshing in a rocket fuel tank, Maxime C.N. Roux, Benjamin A.H. Meunier and Daniele Mari, (abstract)
- 73rd International Astronautical Congress, Paris, September 2022: Characterization of the dampening of liquid sloshing with foam-like materials, Loup Cordey, Maxime C.N. Roux and all, (abstract)